GEM Vehicle
Overview
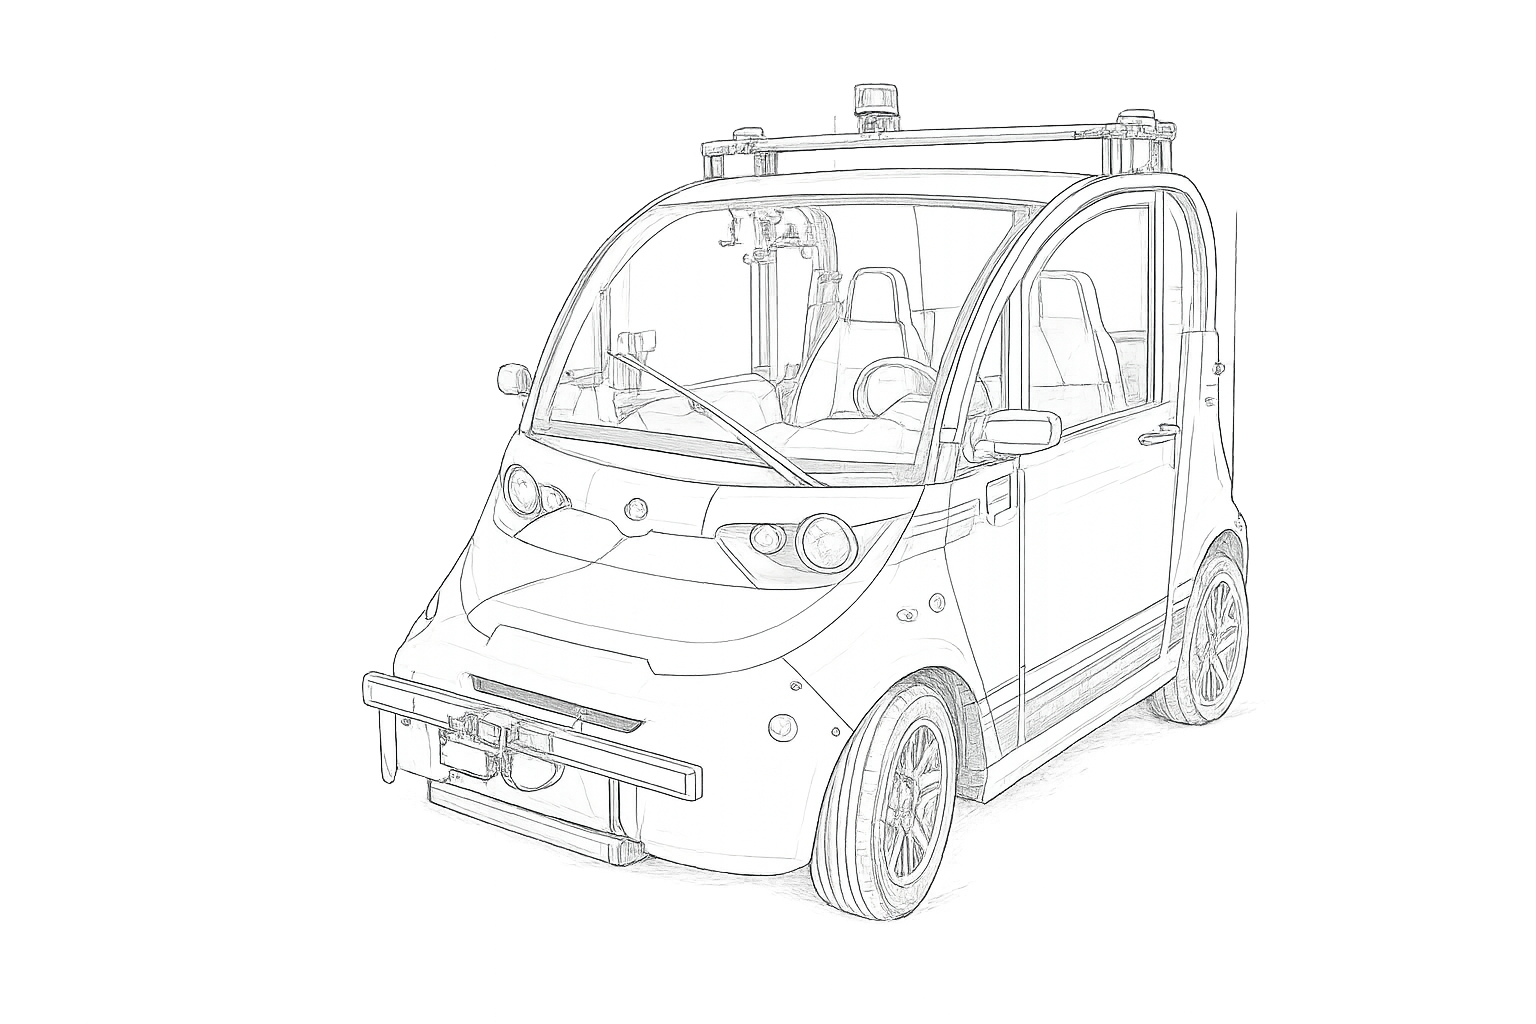
Operate a full-scale GEM vehicle autonomously though a track consisting of a straightaway and two loops without navigating off course. The car must simultaneously have a perception system for stop sign and pedestrian detection.
Objectives
Your system will be evaluated on the following criteria:
- Detect the drivable region (lane following)
- Generate waypoints within driveable region
- Ensure the car stays in the drivable region for the entire journey
- Stop completely and automatically when an obstacle or stop sign is detected
- Resume automatically after stopping
System Modules
Your implementation should cover the following modules:
- Camera-based lane-following controller — lateral and longitudinal control; follows the planned path with possible stops
- Obstacle detector & distance estimator — detects stop signs and pedestrians and estimates their distance
Milestones
| # | Time | Milestone | Description |
|---|---|---|---|
| 1 | Setup | Become comfortable working with GEM hardware and software setup | |
| 2 | Project Pitch | Demo | Run and become familiar with the Joystick controller demo code |
| 3 | Milestone Check-In | Lane following | Integrate and test the lane-following controller on the physical vehicle |
| 4 | Stop Sign Detection | Integrate the stop sign detector and controller that brings the vehicle to a full stop before proceeding. | |
| 5 | Pedestrian Detection | (Groups of 4) Integrate pedestrian detection where the vehicle must wait for two pedestrians to separately cross the track before proceeding | |
| 6 | Full System Evaluation | Evaluate the complete system and measure elapsed time to complete two laps around the track. | |
| 7 | Final presentation | Product launch | Final demo at the end of the semester and launch project site |
Bonus Points
- Drive around a cone that is in the way
- Autonomously detect and park in a parking spot
Primary Mentor
Eric and Yuxi